Who We Are
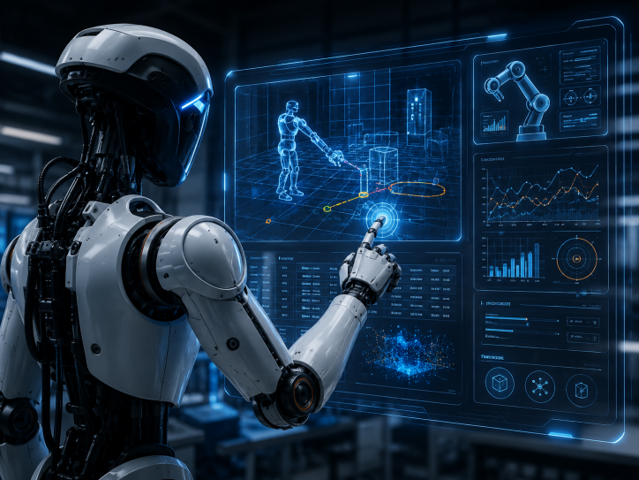
To accelerate the Robotic Innovation Research Scheme, our Hub conducts frontier research at the intersection of Artificial Intelligence, Robotics and Autonomous Systems. Our mission is to develop the next generation of embodied intelligence by advancing world models, autonomous reasoning and collaborative physical AI. We focus on enabling intelligent agents to understand and predict the dynamics of the physical world, perform generalized tasks in complex environments and collaborate effectively with humans and other agents. Through this research, we aim to establish the foundational technologies that will drive the future of Physical AI and real-world intelligent systems.
Project Overview
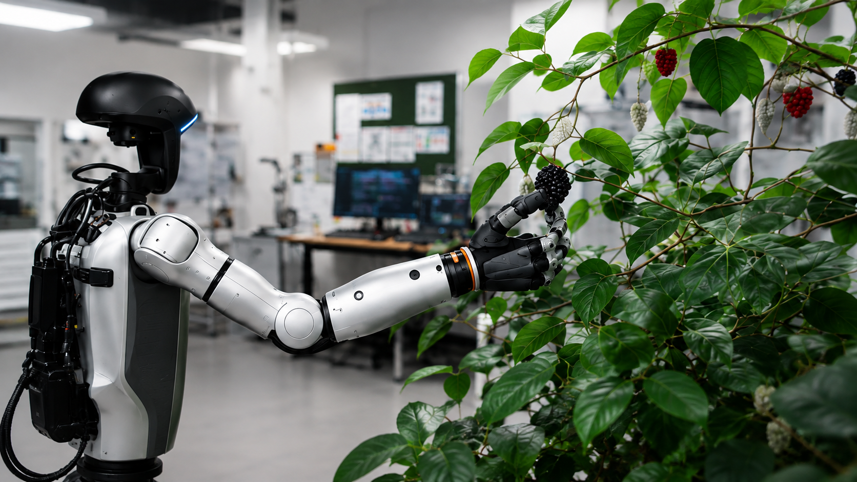
We developed a bisimulation-based formal planning framework that enables a humanoid robot to safely perform diverse manipulation tasks with no retraining. Using a single symbolic model built once from the robot dynamics, the Unitree G1 successfully performs object grasping, elevator-button pressing, and berry harvesting across different environments. Only the task specifications and environment labels need to be updated, enabling rapid adaptation while providing formally certified collision-free motion plans.
Research Focus
Find out more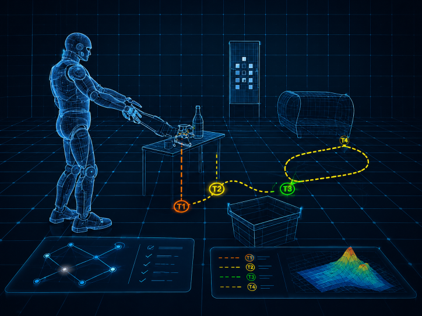
General-Purpose Autonomous Execution
Intelligent planning, adaptation and task execution across diverse environments.
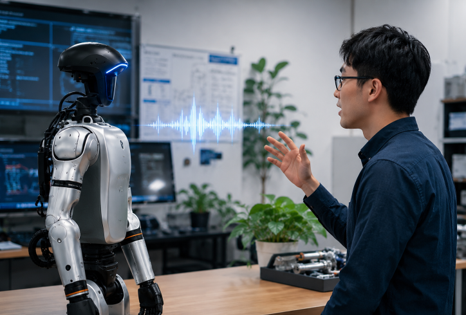
Human-Robot Interaction
Language-guided interaction that enables robots to understand commands and perform the intended actions accurately.
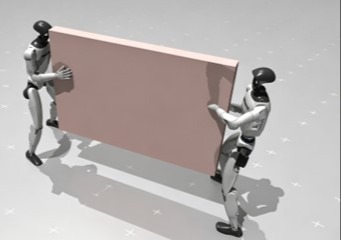
Multi-Humanoid Collaboration
Coordinated multi-robot manipulation for safe and efficient transport of large objects.
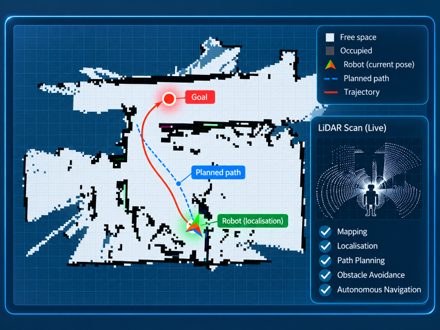
Mapping and Navigation
Robust mapping, localisation and autonomous navigation in complex and dynamic environments.
Task Demonstrations
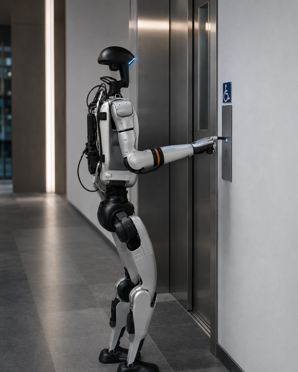
Elevator Button Pressing
The robot autonomously navigates to the elevator and presses the designated floor button using formally verified motion plans, ensuring safety and reliability in dynamic environments.
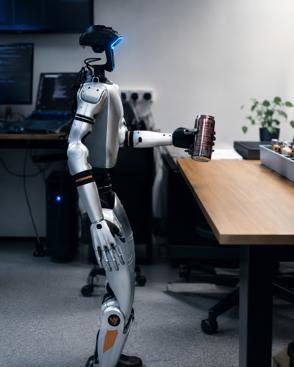
Object Grasping
The robot performs precise object grasping using its dexterous hand, adapting to different object shapes and sizes without any retraining.
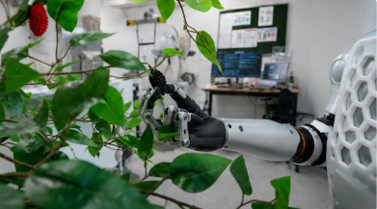
Berry Harvesting
The robot identifies and harvests ripe berries in unstructured environments, demonstrating its ability to handle complex, real-world manipulation tasks.